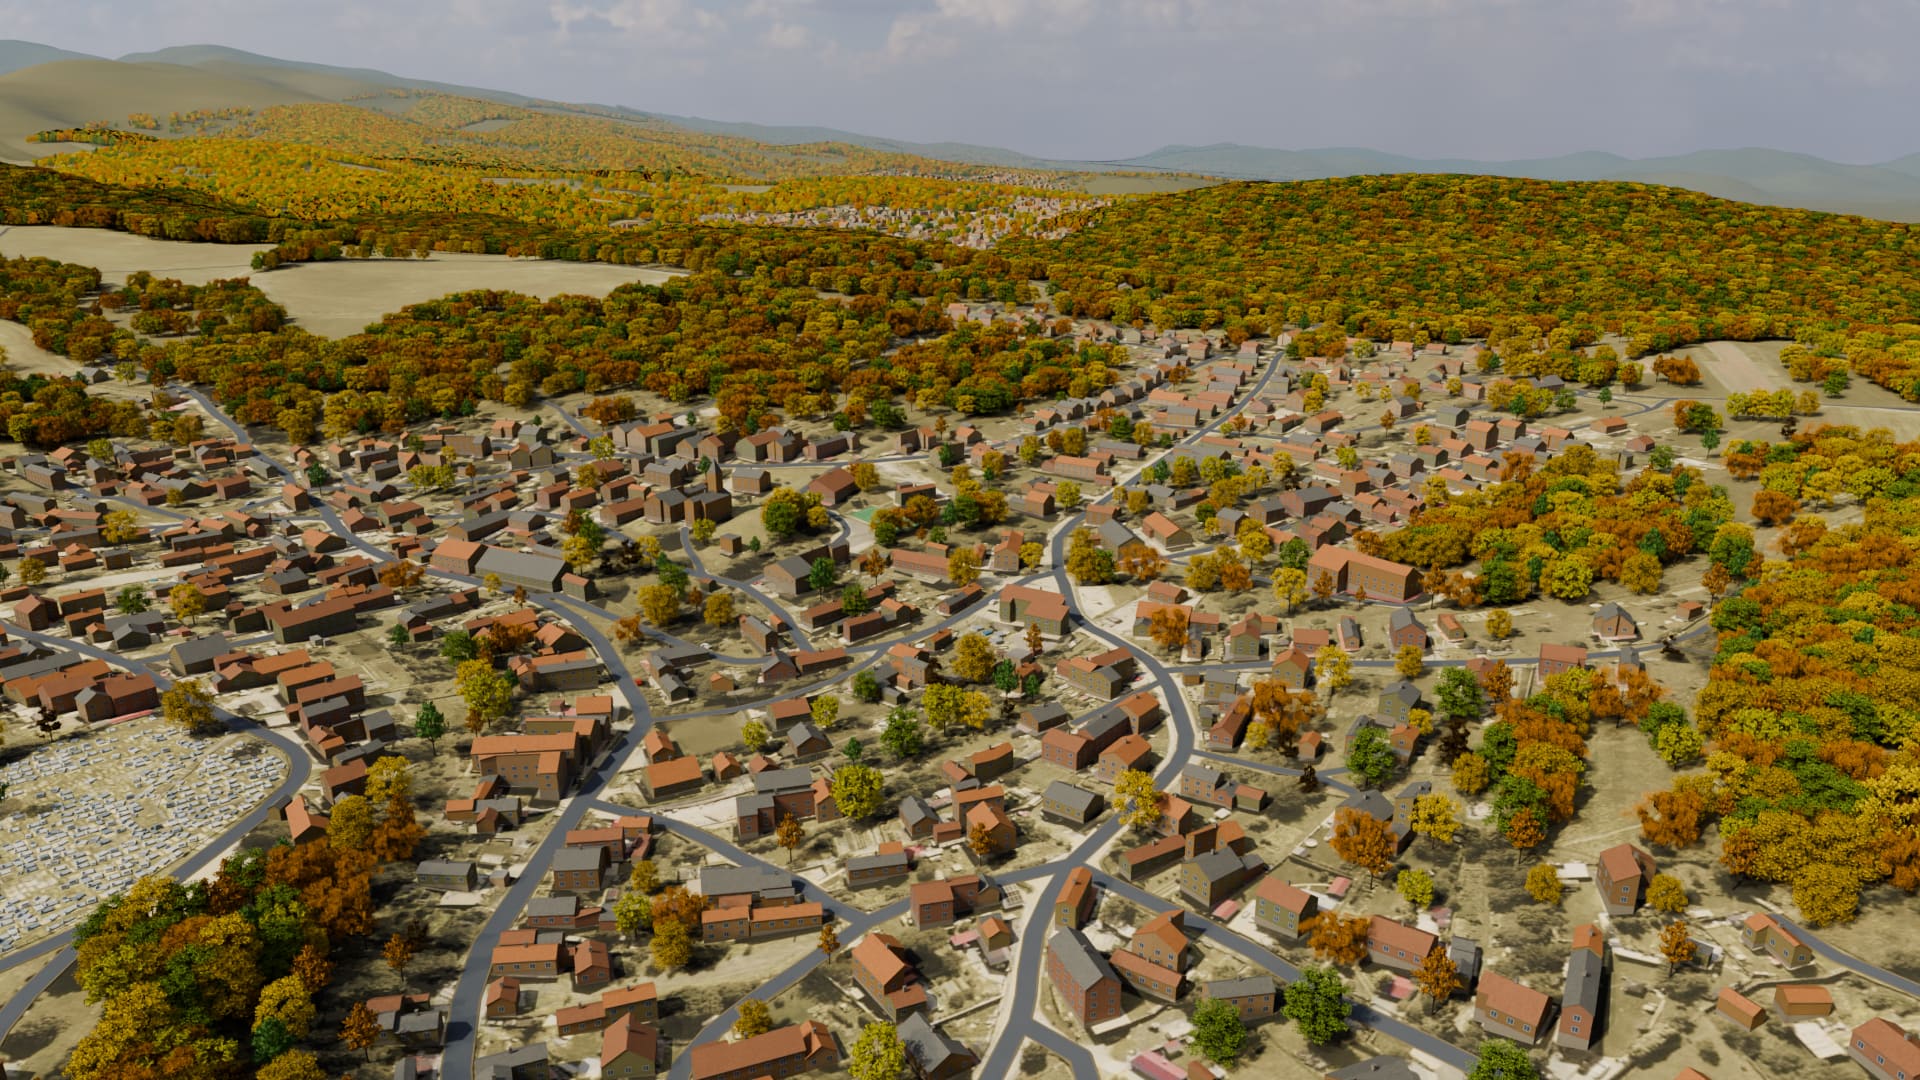
UAV simulation
& navigation
engineering
Validate autonomous aircraft in simulation before they reach the field.
Simulate real terrain, cameras, GPS, launch dynamics, battery behavior, and failure scenarios - with custom models and plugins for your system.
Test what breaks before flight does.
Default simulation environments are clean and predictable. Real flights are not.
We build reproducible environments for testing autonomous aircraft against degraded GNSS, camera imperfections, wind, sensor latency, terrain and failure conditions - while keeping the real PX4, ROS 2 and vision stack in the loop.
Our pipelines can be built on
Autopilots
- PX4
- ArduPilot
Communication & robotics
- MAVLink
- MAVSDK
- ROS
- ROS 2
Simulators
- Gazebo
- Isaac Sim
- FlightGear
- Custom simulation (UE5)
Languages
- C
- C++
- Python
Supported models
- Multirotor UAVs
- Fixed-wing UAVs
- Uncrewed ground vehicles
Open-source contributions
Dynamic terrain for Gazebo
Stream map imagery and elevation around a moving model. Generate terrain meshes and collision surfaces at runtime, with progressive texture detail and local tile caching. Supports Gazebo Harmonic and Jetty.
gz-dynamic-terrain-pluginCamera streaming for PX4
Send rendered camera frames directly to GStreamer for RTP/H.264 streaming in PX4 SITL. Configure multiple cameras independently, with separate destinations, frame rates and bitrates, plus optional NVIDIA encoding with automatic x264 fallback.
px4-gazebo-gstreamer-camera-plugin
What needs to
work before
takeoff?
Tell us what you’re building, what you’ve tried, and where you’re getting stuck. Let’s find the next useful test.
- Your aircraft and flight software
- The environment you need to reproduce
- The failure you want to understand